基于卷积神经网络的横向转角预测方法
2020-08-03 08:05:46曾明如杨向文祝琴
现代电子技术
2020年6期
关键词:数据处理
曾明如 杨向文 祝琴
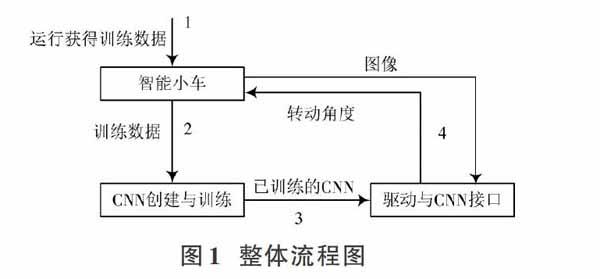
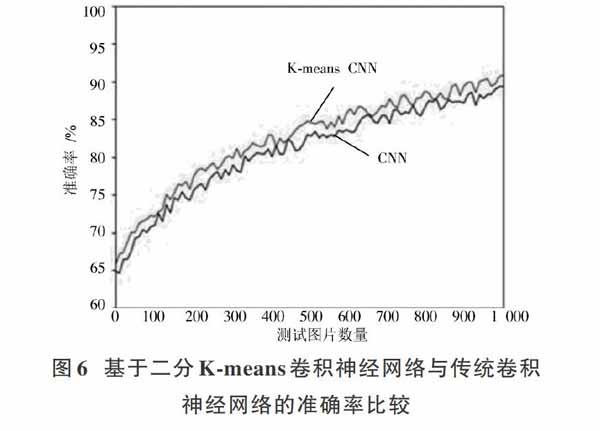
摘 要: 由于智能小车探测周围环境的硬件设备的繁杂,将卷积神经网络与摄像头结合来探测周围环境越来越成为研究的热点。然而,单纯地使用卷积神经网络处理摄像头的数据来控制小车的转角,存在训练时间久、准确率不高的问题。针对上述问題,该文提出了将摄像头的数据经过无监督的二分K?means聚类方法之后,再将聚类结果作为卷积神经网络的输入,最终预测小车转角。实验结果证明,该网络结构可以有效地提高网络的训练速度,并提高网络的准确率。
关键词: 转角预测; 卷积神经网络; 数据处理; 周围环境探测; 网络训练; 结果分析
中图分类号: TN820.5?34; TP391.41 文献标识码: A 文章编号: 1004?373X(2020)06?0140?04
Method of lateral turning angle prediction based on CNN
ZENG Mingru, YANG Xiangwen, ZHU Qin
(School of Information Engineering, Nanchang University, Nanchang 330031, China)
Abstract: As the intelligent little vehicle′s hardware equipments for detecting the surrounding environment are too complex, it has become a research hotspot to combine convolutional neural network with camera to detect the surrounding environment. However, if the convolutional neural network is applied alone to process the data of the camera for the turning angle control of the little vehicle, the training time would be long and the accuracy would be low. Based on the above problems, the camera data is processed by means of the unsupervised binary k?means clustering method, and then the clustering result is taken as the input of the convolutional neural network, so as to predict the little vehicle′s turning angle. The Experiment results show that the network structure can effectively improve the training speed and accuracy of the network.
Keywords: turning angle prediction; convolutional neural network; data processing; surrounding environment detection; network training; result analysis
0 引 言
计算机技术和人工智能的发展使得车辆的自动驾驶受到越来越多的关注,其中车辆的横向控制系统是自动驾驶中一个重要组成部分。在车辆的横向控制中主要分为两个阶段:获得车辆外界的复杂环境信息;对信息处理分析之后判断下一时刻车辆的前轮转角。
传统的智能小车的横向控制系统,都是通过超声波、雷达、红外线等多种传感器结合的方法收集信息,建立模糊控制规则从而预测车辆的前轮转角实现避障[1]。多种传感器的结合使用,是为了小车探测复杂的环境来预测下一时刻的转角。但随着计算机和人工智能的发展,卷积神经网络在复杂图像环境下表现出非常好的容错性和鲁棒性[2]。因此利用卷积神经网络和摄像头结合来处理车辆外界的复杂环境信息成为一种新的可行方法,该方法相较于传统的方法避免了使用冗余的硬件设备,并且具有更好的适应复杂环境的能力[3]。……
登录APP查看全文
猜你喜欢
中学生数理化·自主招生(2022年9期)2022-05-30 10:48:04
心理学报(2022年4期)2022-04-12 07:38:02
水泵技术(2021年3期)2021-08-14 02:09:20
电子测试(2018年4期)2018-05-09 07:28:12
当代化工研究(2016年9期)2016-03-20 16:22:13
中国惯性技术学报(2015年1期)2015-12-19 13:12:17
计算机工程(2015年4期)2015-07-05 08:28:04
联合国青年技术培训(2014年7期)2014-04-12 00:00:00
中国质量与标准导报(2014年7期)2014-02-28 22:24:35
测绘科学与工程(2013年3期)2013-03-11 15:07:36