磨辊堆焊修复路径规划
2021-02-08 13:31:26周奥博王微伟王喜临刘爱国
机械制造文摘·焊接分册
2021年6期
周奥博 王微伟 王喜临 刘爱国
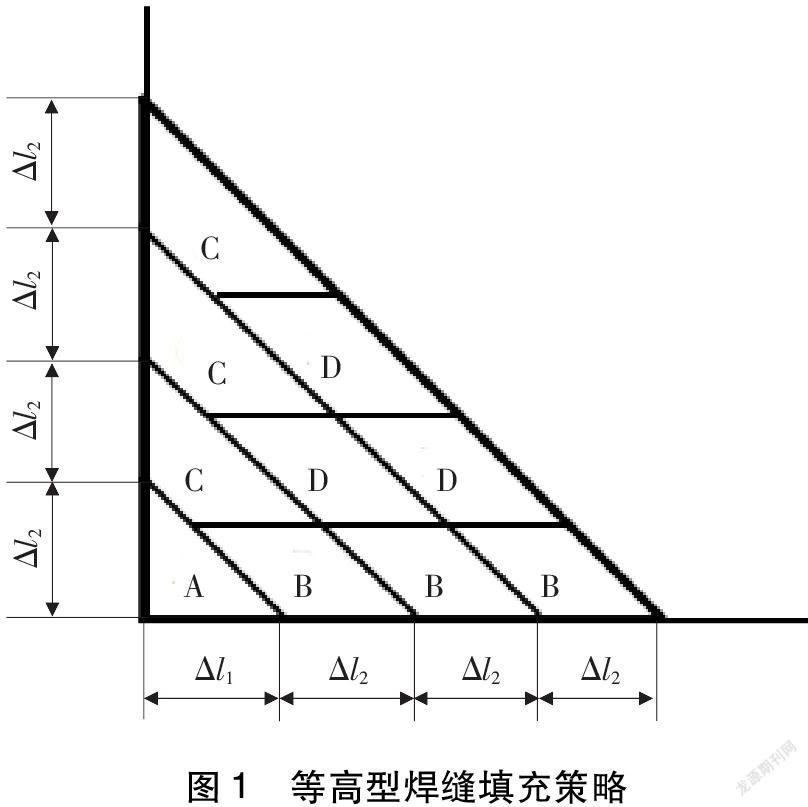
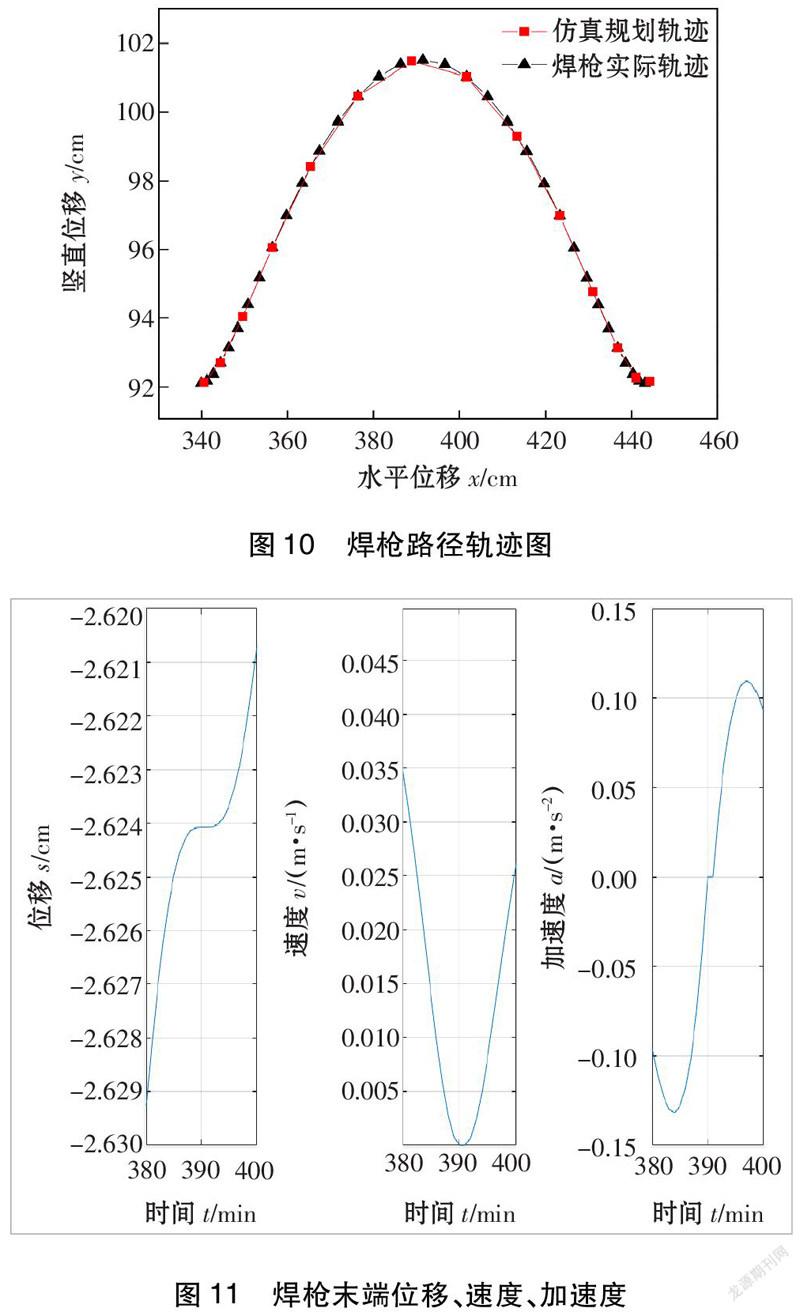
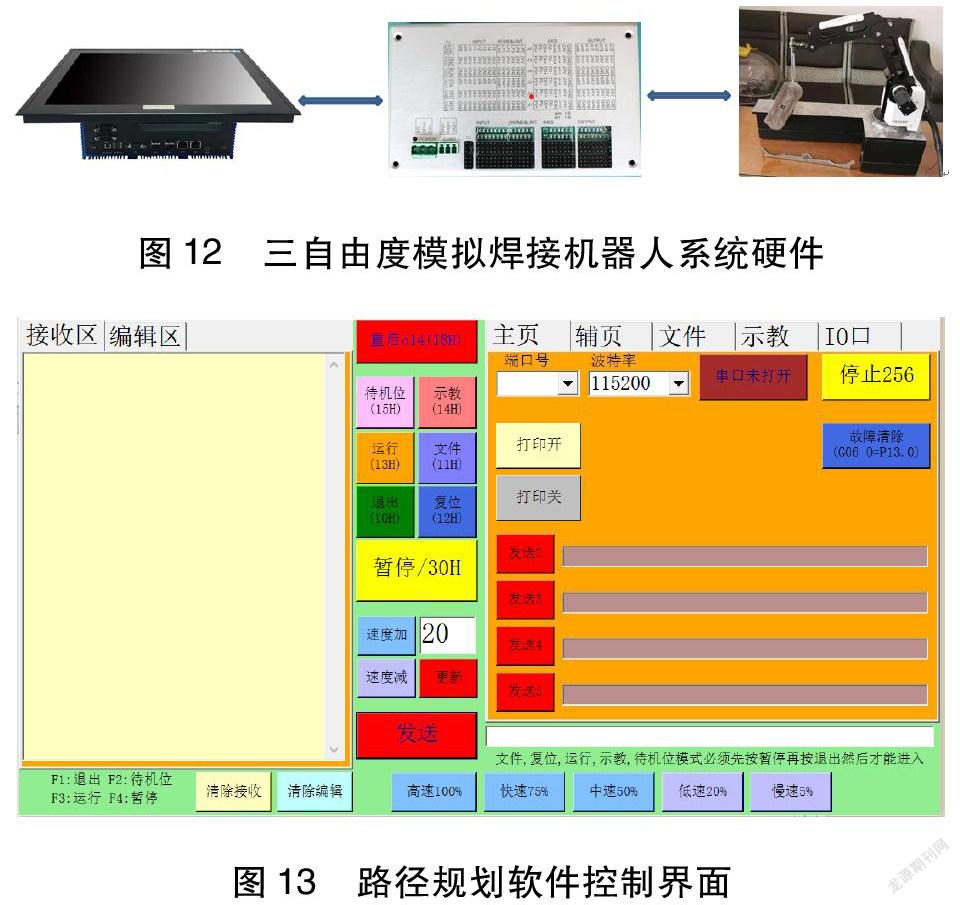
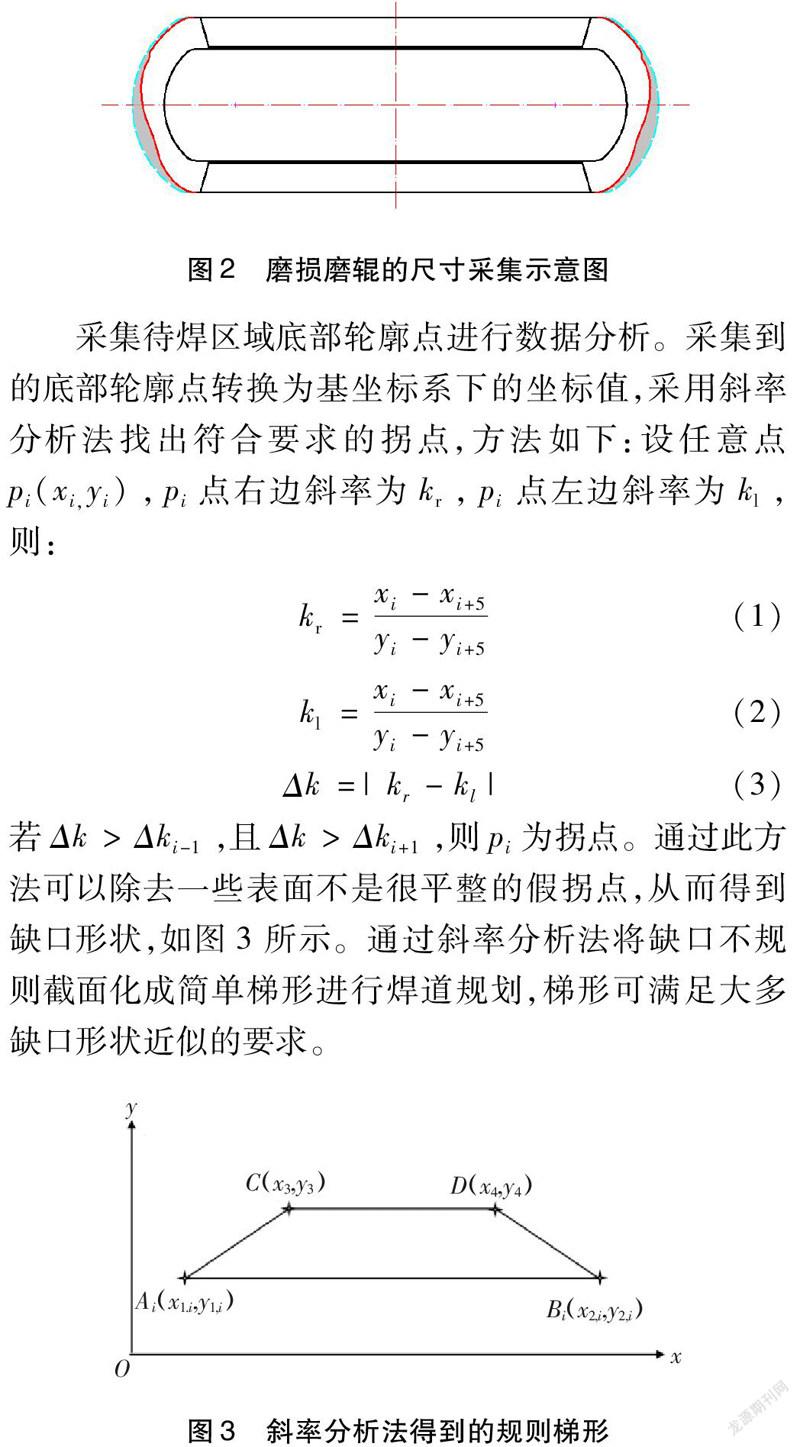
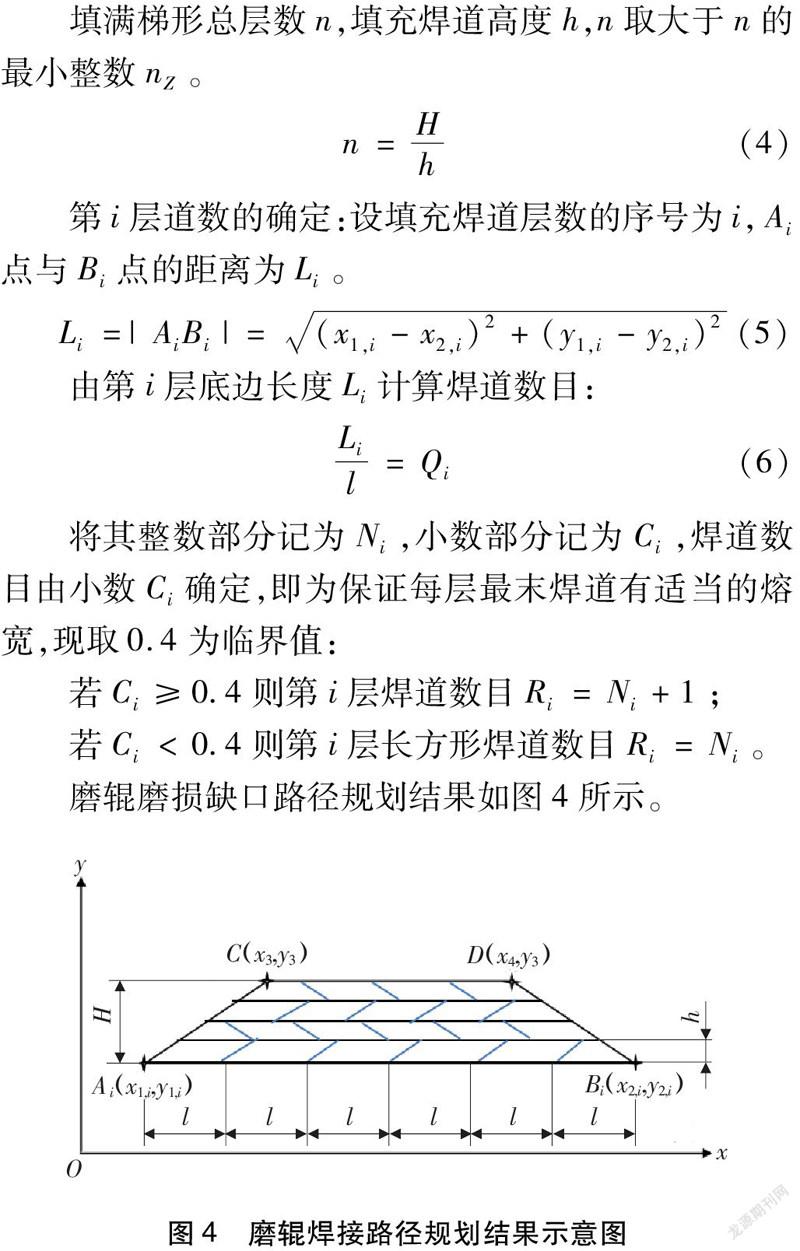
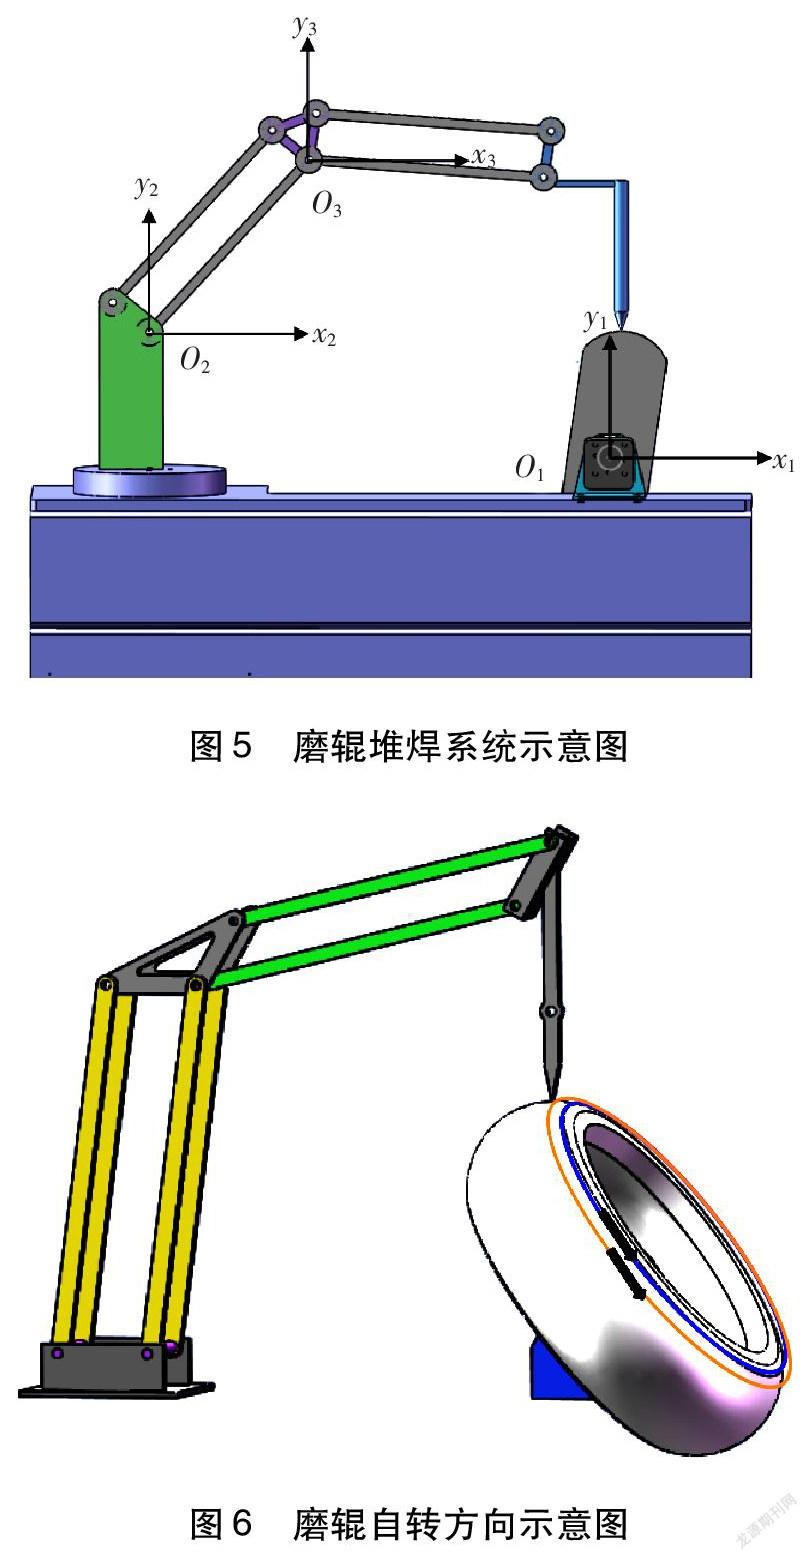
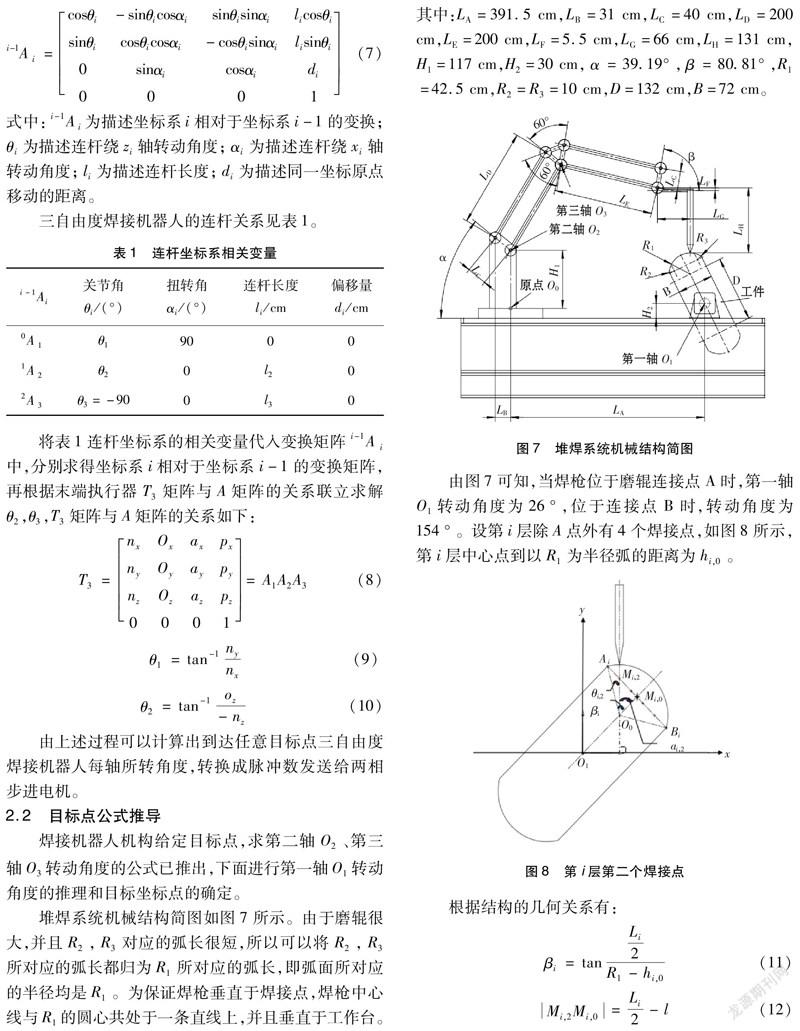
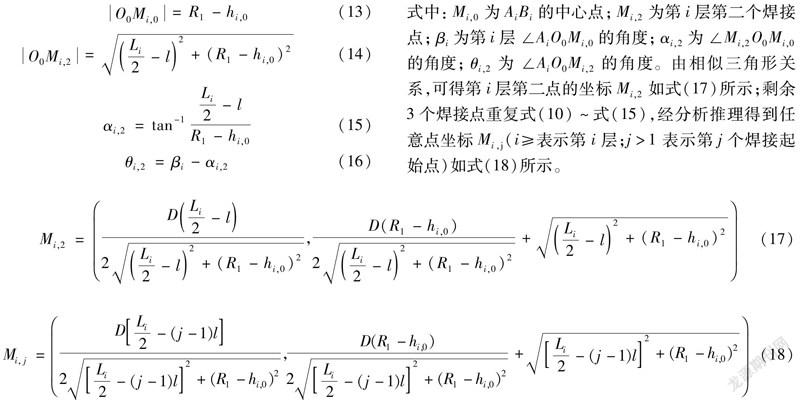
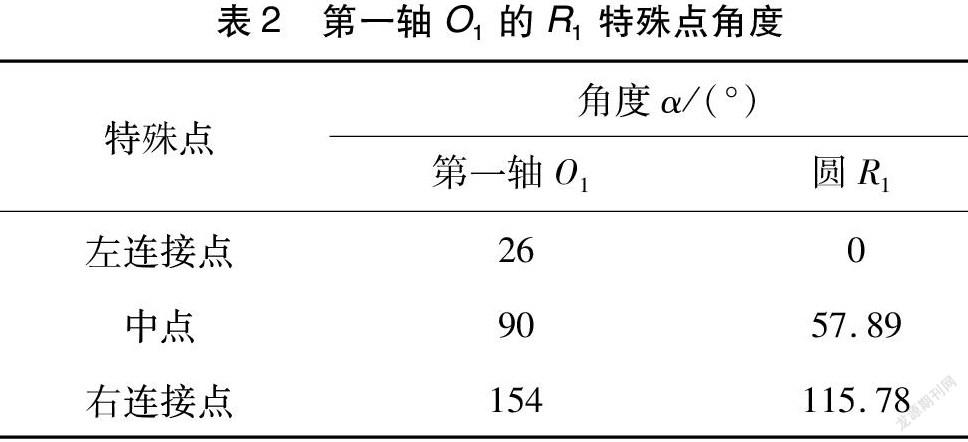
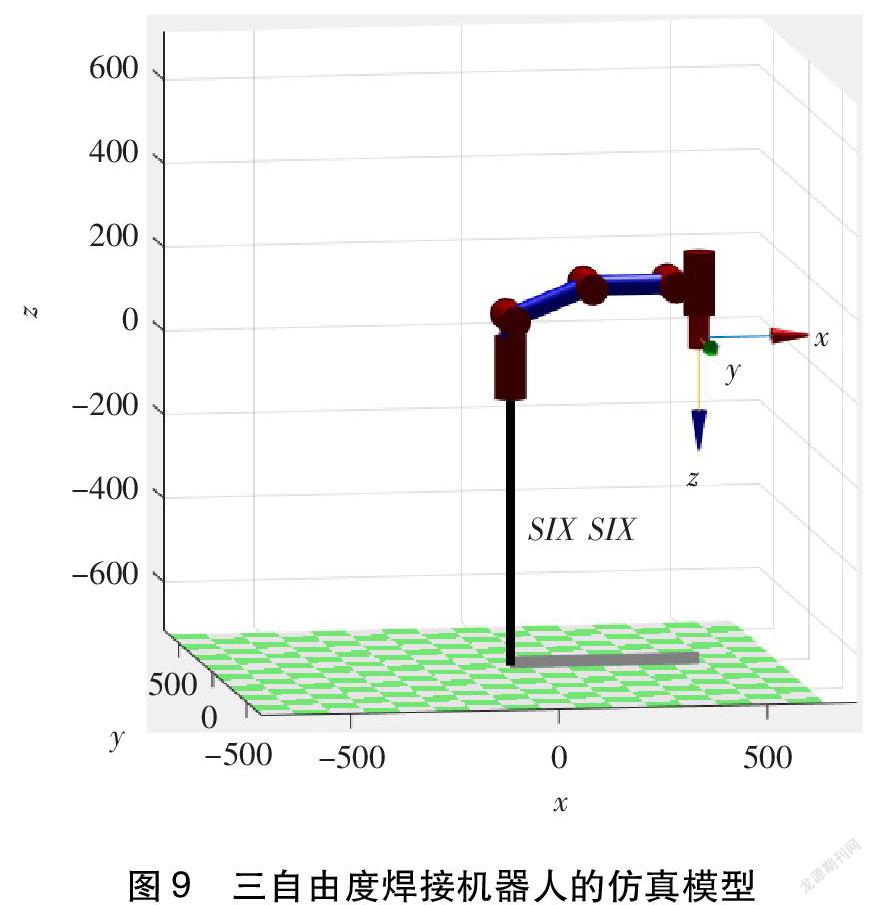
摘要:在等高型和等面积型焊缝填充策略的基础上,提出了改进的磨辊堆焊焊缝填充策略,进行了磨辊堆焊焊道路径规划;在磨辊待焊区域焊道排布结果的基础上,通过对堆焊系统机械结构的分析,推导出了路径规划的焊接目标点公式与每一目标点所对应的磨辊转轴转动角度,以及焊接机械臂转动角度,并进行了焊接机械臂末端的运动学仿真。结果表明,所提出的焊缝填充策略和堆焊路径规划方案可以保证机械臂平滑稳定的地到达路径规划后的任意一点,机械臂可以稳定地启动和停止。焊缝填充策略合理,堆焊路径规划方案正确。
关键词:焊接路径规划;焊接机械臂;联动机构;软件仿真;多层多道焊
中图分类号:TG 409
Abstract:Based on the equal-height and equal-area weld filling strategies, an improved grinding roll surfacing weld filling strategy was proposed, and the path planning of the grinding roll surfacing weld bead was carried out. On the basis of the result of welding pass arrangement in the area to be welded by grinding roller, the welding target point formula of the path planning and the rotation angle of the grinding roller shaft corresponding to each target point, as well as rotation angle of welding robot arm, were deduced through the analysis of the mechanical structure of surfacing system, and the kinematics simulation of the end of the welding robot arm was carried out. The results showed that the proposed weld filling strategy and surfacing path planning scheme could ensure that the robotic arm reached any point after the path planning smoothly and stably, and the robotic arm could start and stop stably. The weld filling strategy was reasonable, and the surfacing welding path planning scheme was correct.
Key words:welding path planning;welding robot arm;link gear;simulation software;multi-layer and multi-pass welding
0 前言
20世纪60年代以来,为提高能源利用率,越来越多的火力发电厂采用中速磨煤机[1-2]ADDINNE.Ref.{966E3546-8DE0-49E1-B8FD-D7E87A891E83}作为制粉系统的磨煤工具。中国出产的煤种类繁多、杂质含量高、可磨性非常差,再加上工人经验不足,导致磨煤机磨辊、磨盘过快地磨损。为了降低生产成本,采用焊补的方式对磨损缺口进行修复。目前国内大多数发电厂主要依靠于人工焊补。但是人工焊补存在着许多问题例如效率低、焊接质量差、工作环境差以及弧光污染、粉尘污染对工人健康的影响等。采用智能焊接机器人进行焊补是解决该问题的有效方法。对于不规则的磨辊磨损缺口,焊道的路径规划是开发磨辊磨损缺口智能修复系统要面对的首要问题。……
登录APP查看全文