基于 HJI理论的双半球胶囊机器人姿态非线性控制方法
2021-08-20 00:22:33刘冠喜张永顺
机电工程技术
2021年11期
刘冠喜 张永顺
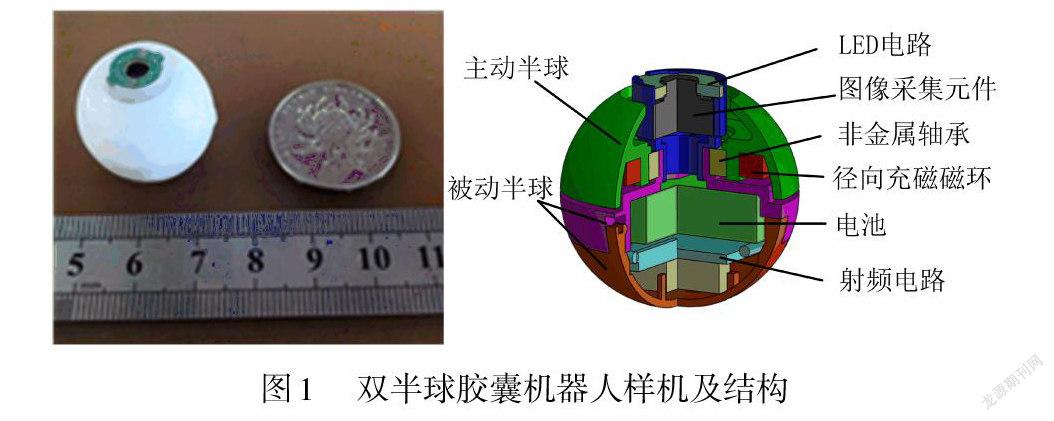


摘要:考虑到自主研发的双半球胶囊机器人系统不确定性以及外界扰动等非线性特征问题,提出了一种基于 Hamilton-Jacobi不等式(HJI)理论的双半球胶囊机器人滑模鲁棒非线性控制策略。通过拉格朗日动力学原理建立双半球胶囊机器人被动模态的动力学模型,并将 Hamilton-Jacobi不等式理论应用于设计滑模鲁棒的控制律来确保控制系统的稳定性。此外,通过 Lyapunov方程验证了该双半球胶囊机器人基于 HJI理论的滑模鲁棒控制系统的有效性,并对所设计的控制器进行了仿真实验,仿真和实验结果表明所设计的控制策略能有效地抑制外部干扰对控制误差的影响,提高了双半球胶囊机器人系统的控制精度。
关键词:双半球胶囊机器人;拉格朗日动力学;HJI理论;滑模鲁棒控制
中图分类号:TP242文献标志码:A
文章编号:1009-9492(2021)11-0026-04开放科学(资源服务)标识码(OSID):
Nonlinear Posture Control Method of Dual Hemisphere Capsule Robot Based on HJI Theory
Liu Guanxi ,Zhang Yongshun
(Key Laboratory for Precision & Non-traditional Machining of Ministry of Education, Dalian University of Technology, Dalian,Liaoning 116024, China)
Abstract: Considering the nonlinear characteristics of self-developed dual hemisphere capsule robots(DHCRs) such as indeterminate and external disturbances, a sliding mode robust control strategy for the DHCR based on Hamilton-Jacobi inequality(HJI) theory was proposed. The dynamic model of the passive mode of the DHCR was established by Lagrangian dynamics principle, and the HJI inequality theory was applied to design the sliding mode robust control law to ensure the stability of the control system. In addition, the effectiveness of the control system based on the HJI theory was verified through the Lyapunov equation, and simulation experiments on the designed controller was conducted. Simulation and experimental results show that the control strategy can effectively suppress the influence of external interference on the control error, and improve the control accuracy of the DHCR.
Key words: dual hemisphere capsule robot; Lagrange dynamics; HJI theory; sliding mode robust control
0 引言
目前,可代替內窥镜检查的胶囊内窥镜机器人取得了较快的发展[1-4],与繁琐的传统内窥镜相比,胶囊内窥镜由于具有安全,无痛等特征,可望在复杂环境中执行医学诊疗任务。按照驱动方式,胶囊内窥镜可分为被动式和主动式胶囊内窥镜。主动式胶囊内窥镜也称为胶囊机器人,主要包括电驱动式和磁驱动式胶囊机器人。由于磁驱动胶囊机器人可实现无缆驱动,并避免了复杂的行走机构,因此,磁驱动胶囊机器人具有良好的应用前景,并迅速成为国内外的研究热点。大连理工大学胶囊机器人课题组提……
登录APP查看全文