一种教学用采摘竞赛机器人
2021-08-21 19:03:47罗家宁贺泉张思豪史颖刚刘利王转卫
机电工程技术
2021年12期
罗家宁 贺泉 张思豪 史颖刚 刘利 王转卫

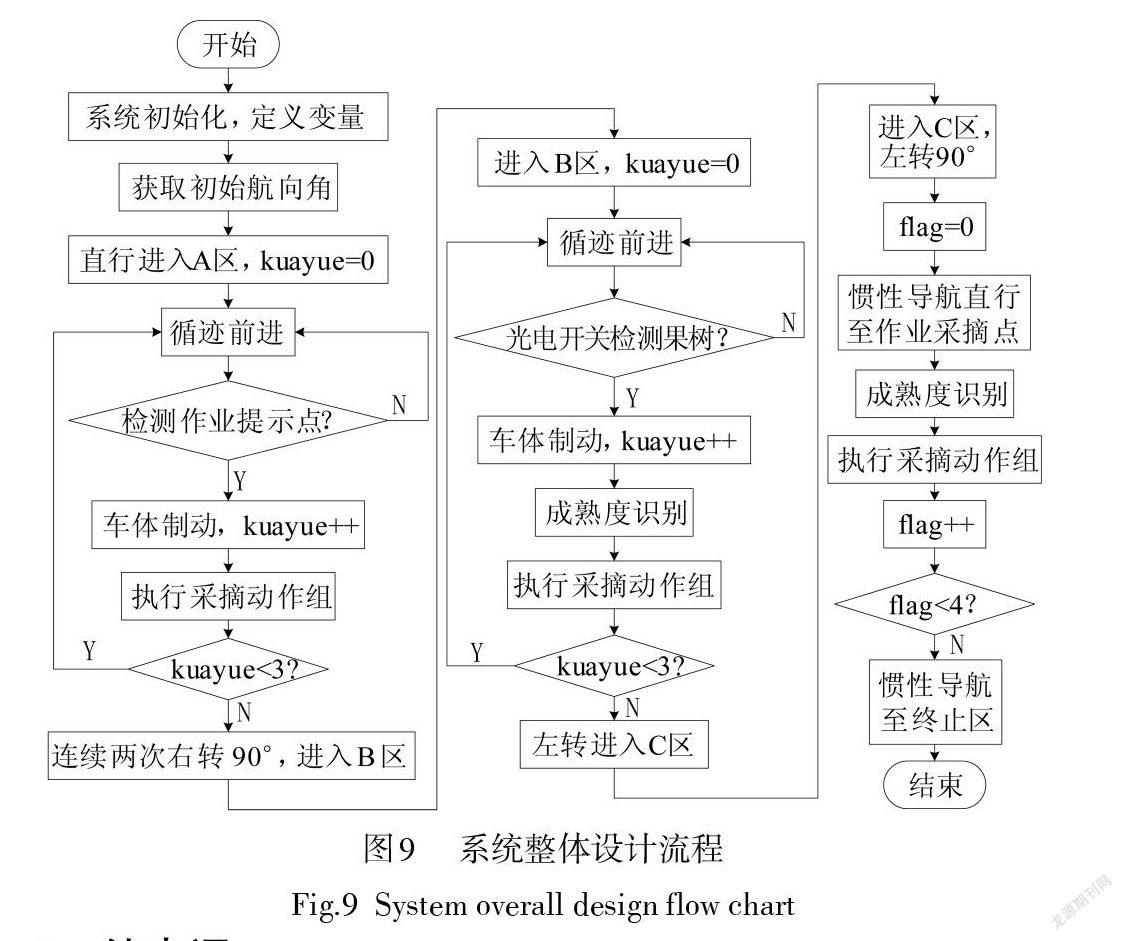
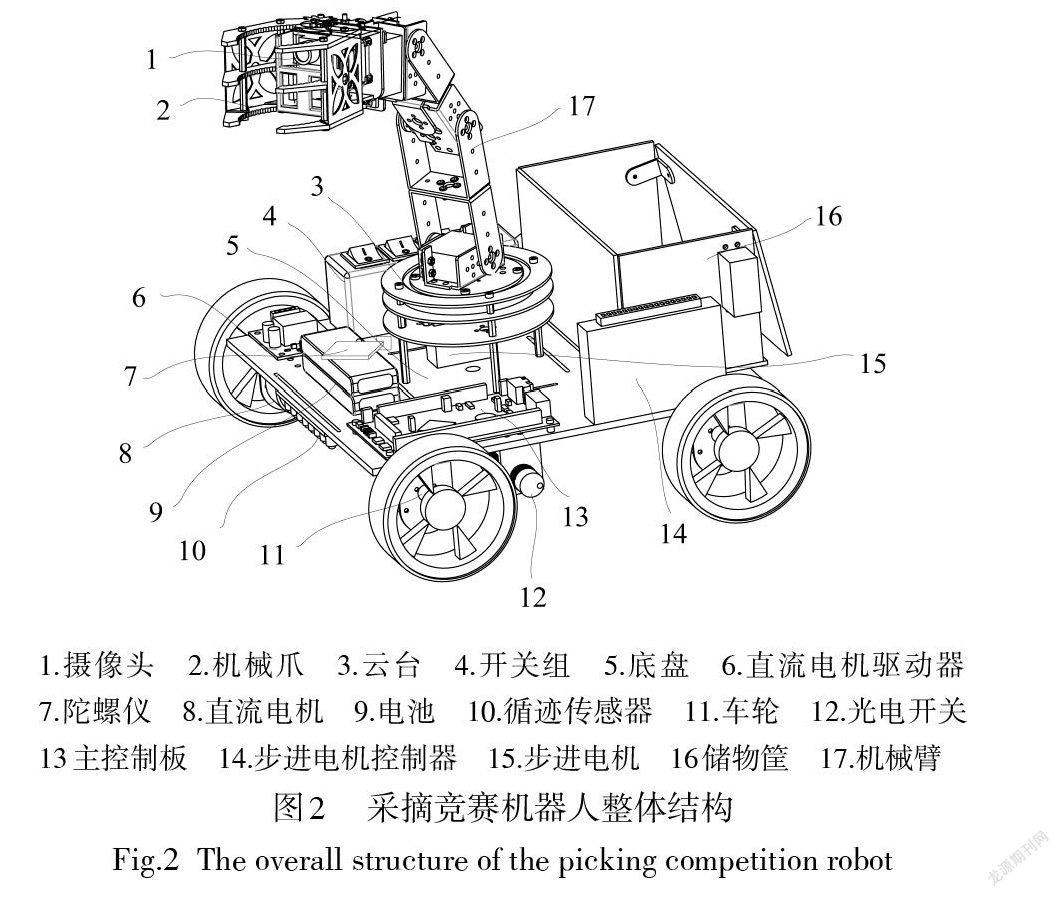
摘要:针对中国机器人大赛采摘机器人子项目,设计了一种教学用采摘竞赛机器人。首先,根据竞赛要求,设计教学用采摘机器人的机械系统,确定了四轮独立驱动的电机布局及差速转向的轮式结构;设计了四自由度串联机械臂,二指回转型机械爪和自动卸载的储物筐。以 STM32F103ZET6单片机为核心,搭载底盘控制模块、颜色识别模块和采摘机械臂模块,构建了采摘机器人的控制系统。根据比赛要求和流程,编写了机器人基本运动子程序、颜色识别子程序、机械臂控制子程序以及系统整體流程。并搭建实物进行测试,结果显示该设计满足竞赛基本要求,能够为学生参加竞赛提供一定的参考。
关键词:教学机器人;机械系统;控制系统;程序设计;视觉识别
中图分类号:TP242 文献标志码:A 文章编号:1009-9492(2021)12-0131-04
A Picking Competition Robot for Teaching
Luo Jianing ,He Quan ,Zhang Sihao ,Shi Yinggang ※, Liu Li ,Wang Zhuanwei
(College of Mechanical and Electronic Engineering, Northwest A&F University, Xianyang, Shaanxi 712100, China)
Abstract: Aiming at the picking robot sub project of China robot competition, a picking competition robot for teaching was designed. Firstly, according to the competition requirements, the mechanical system of the picking robot for teaching was designed, and the motor layout of four-wheel independent drive and the wheel structure of differential steering were determined. Four degree of freedom series manipulator, two finger rotary mechanical claw and automatic unloading storage basket were designed. Taking STM32F103ZET6 single chip microcomputer as the core, equipped with chassis control module, color recognition module and picking manipulator module, the control system of picking robot was constructed. According to the competition requirements and process, the robot basic motion subroutine, color recognition subroutine, manipulator control subroutine and the overall process of the system were written. The results show that the design meets the basic requirements of the competition and can provide some reference for students to participate in the competition.
Key words: teaching robot; mechanical system; control system; program design; visual identity
0 引言
机器人竞赛是培养学生创新思维和能力的重要途径,设计一款面向教学的采摘竞赛机器人,可以为各高校学生提供机器人课程系统学习与实训的机会,从而更好地理解采摘竞赛机器人,在实践中掌握基本专业技能[1]。
果园采摘机器人竞赛是中国机器人大赛的子项目,比赛场地如图1所示。起点区、终止区和储存区均为矩形区域,可用于储存收集果实[2]。本竞赛场地设有机器人行走引导线,机器人沿引导线从起点区出发,按采摘的难易度,依次经过 A区、B区、和 C区,最后到达终止区,完成自主循迹、语音播报、目标识别、果实采摘、收集和运输等功能。……
登录APP查看全文