RTG大车自动纠偏系统设计和纠偏策略
2021-04-30 21:22:22杨阳王宝磊韩佳琦
上海海事大学学报
2021年1期
关键词:实验
杨阳 王宝磊 韩佳琦
摘要:
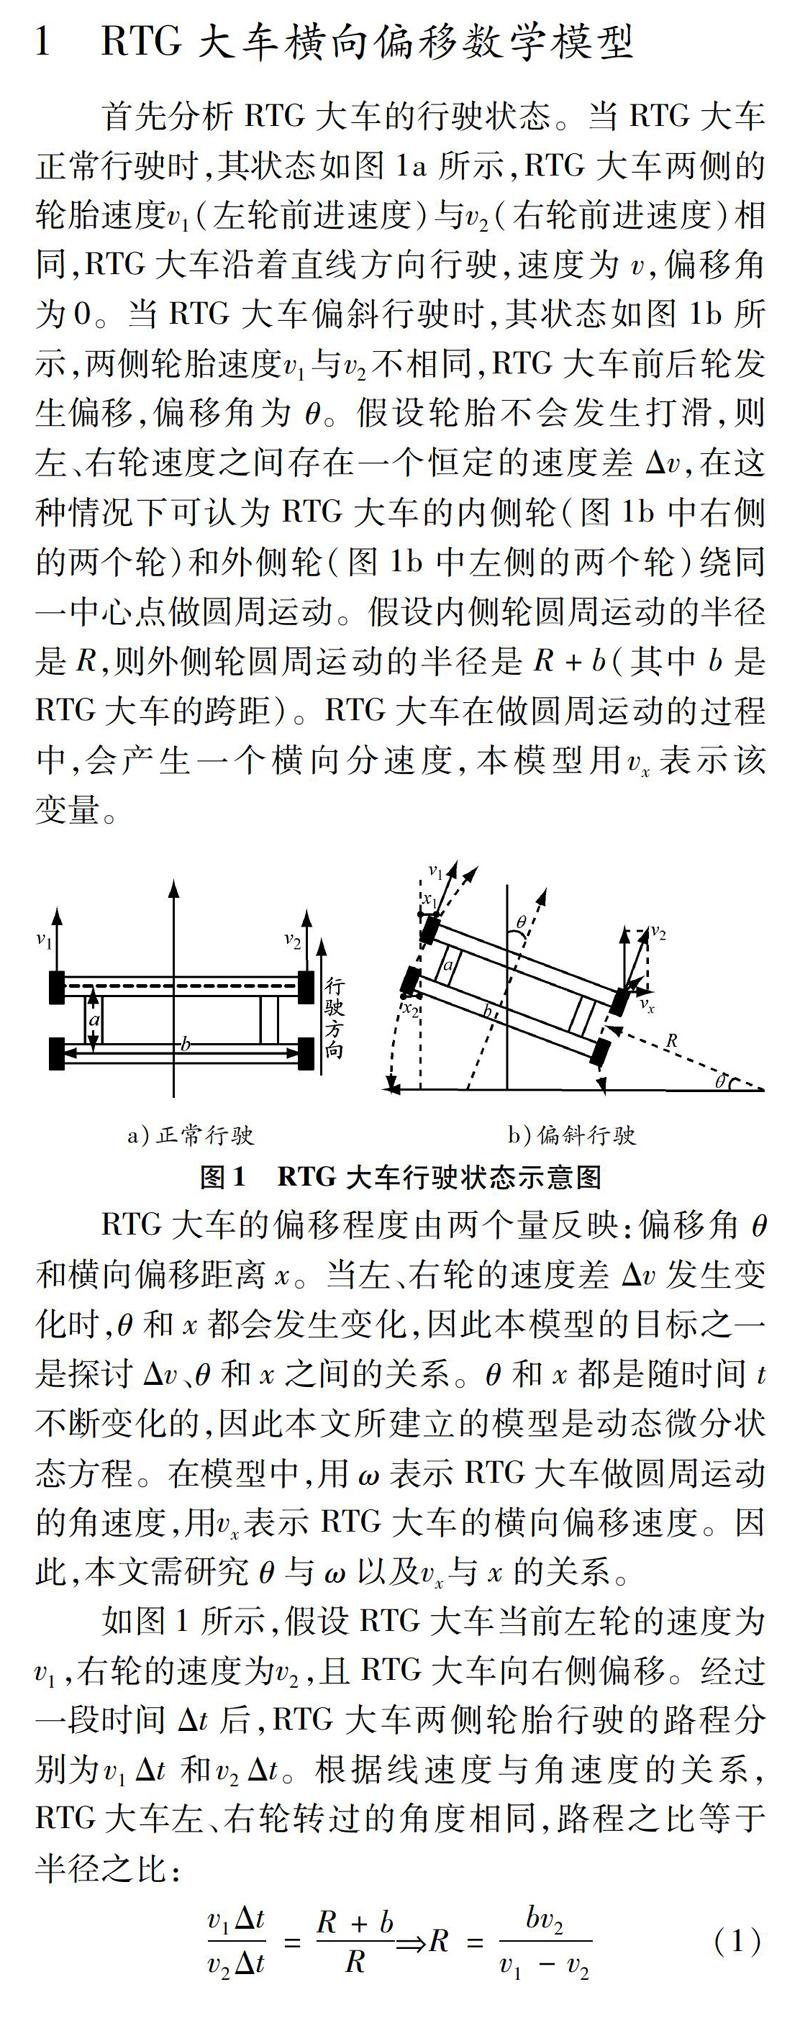
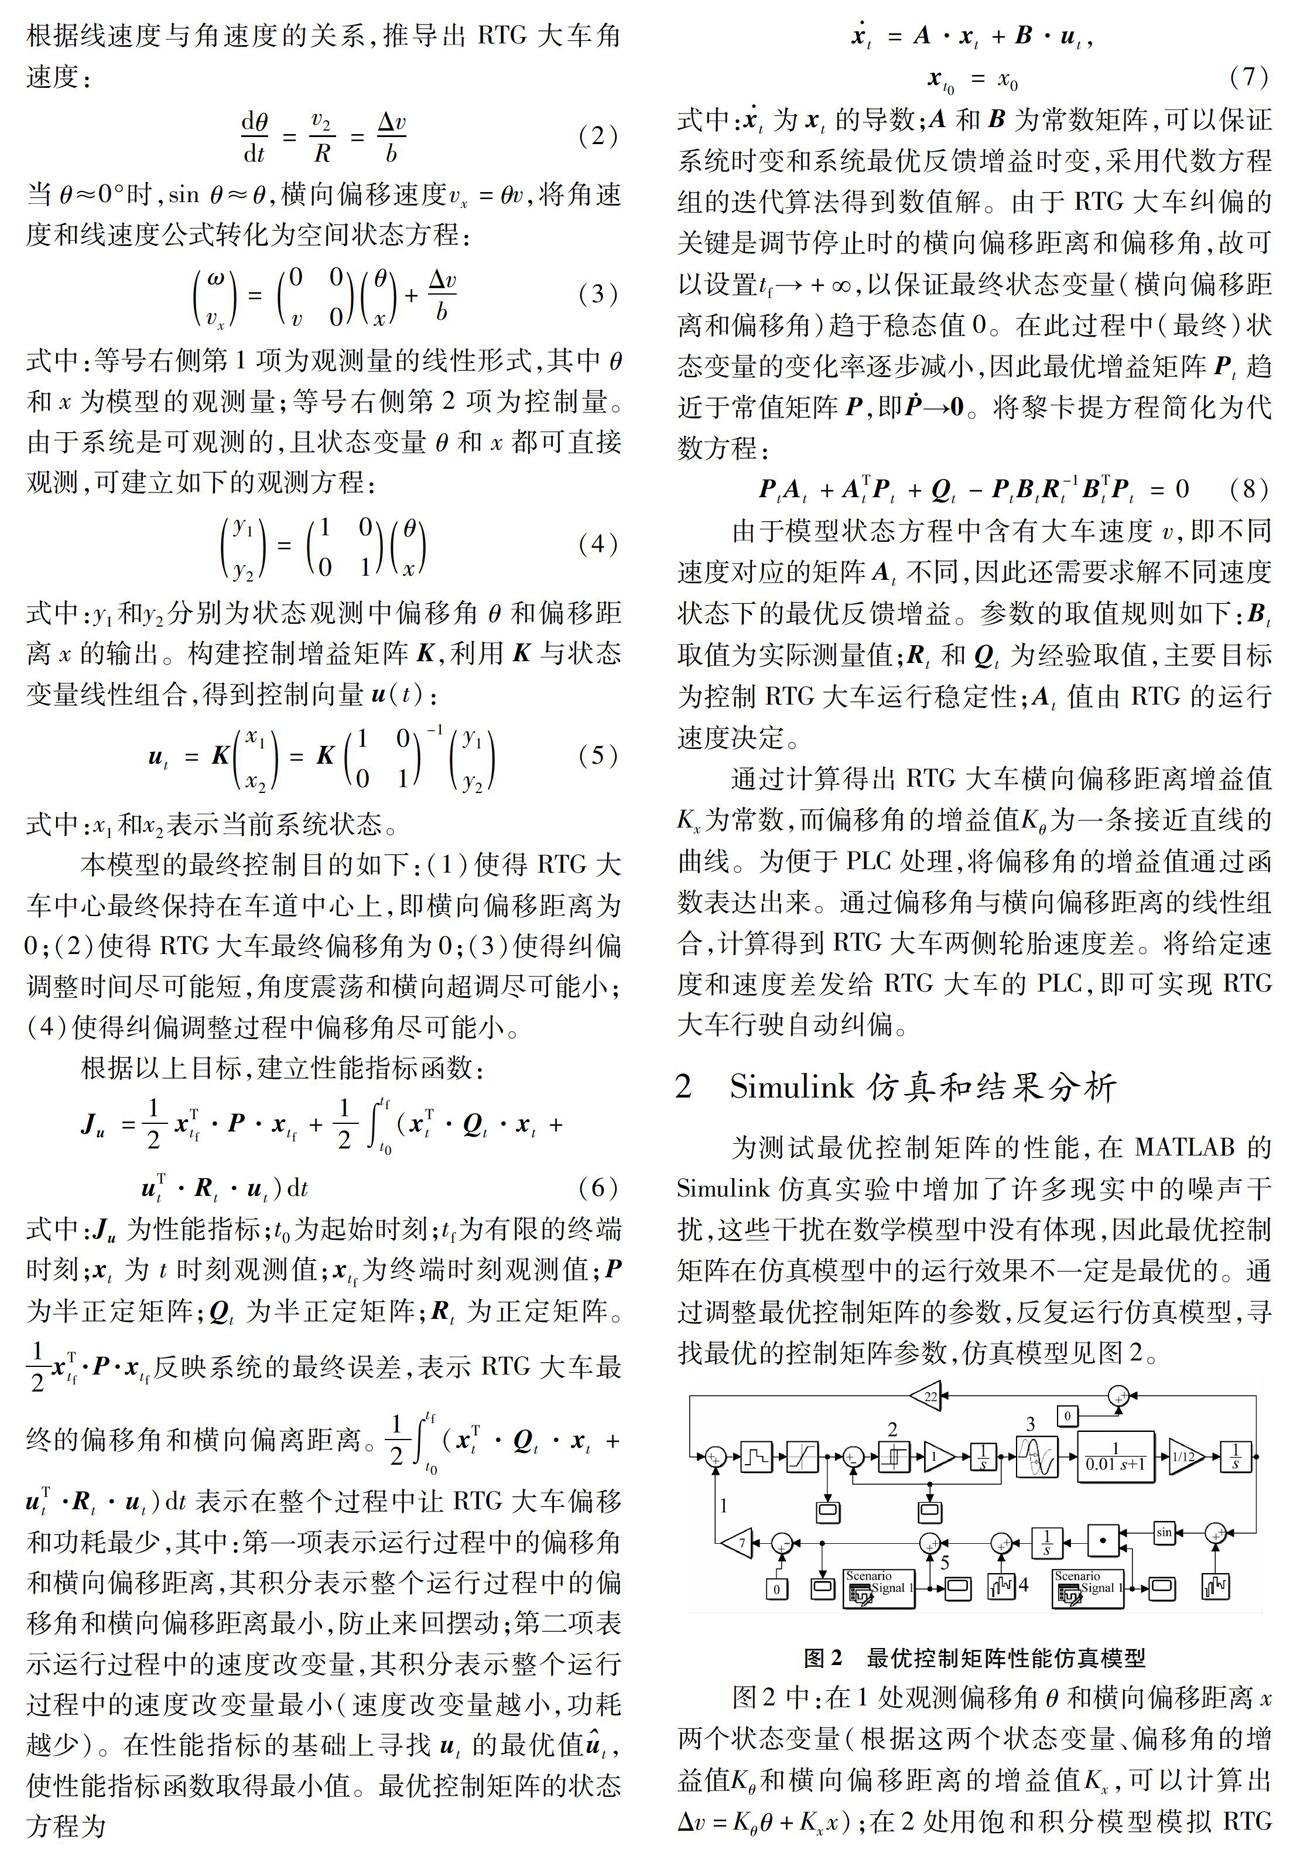
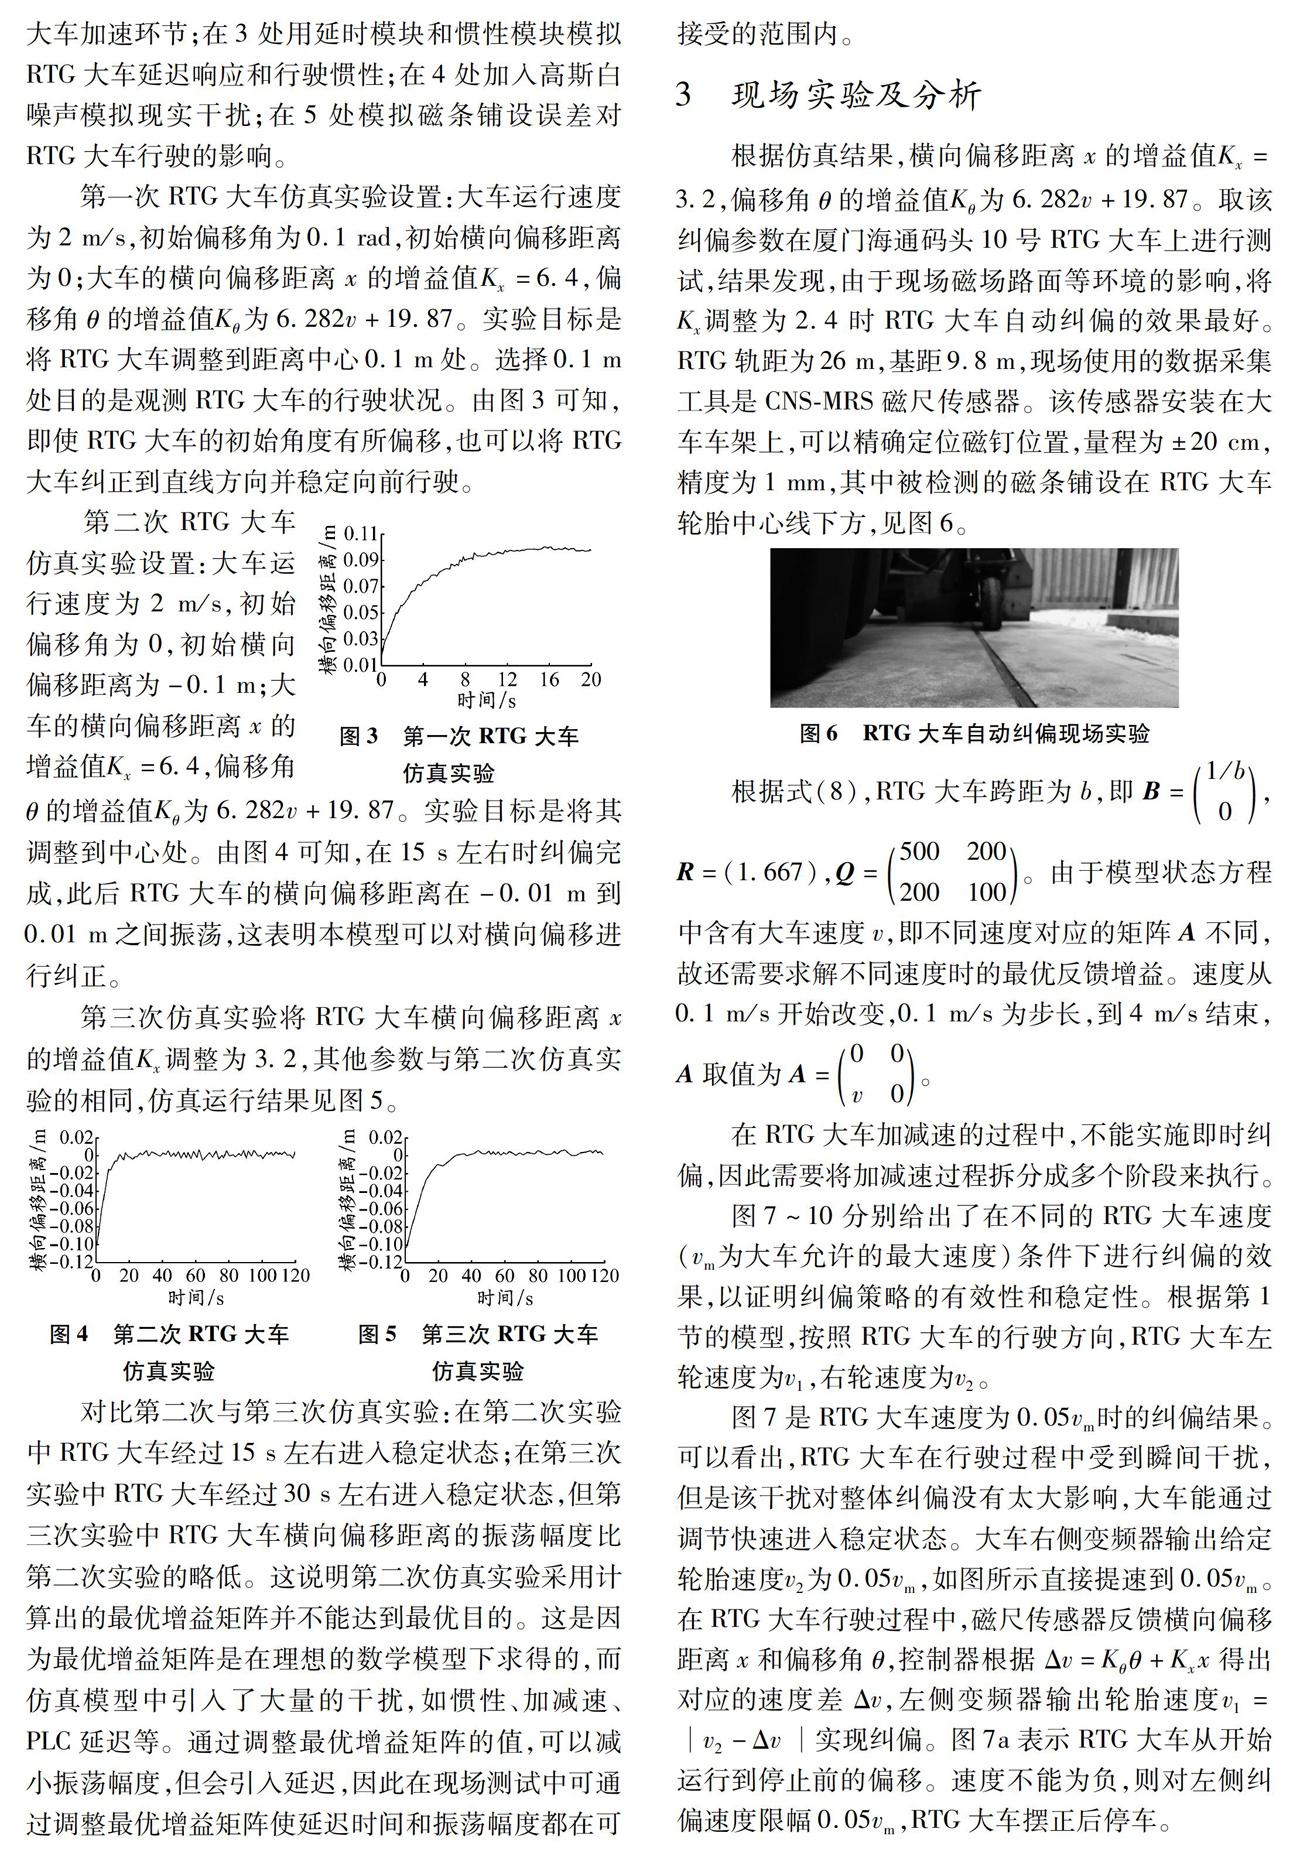
针对传统集装箱码头轮胎式龙门起重机(rubber-tyred gantry crane,RTG)大车在直线行驶过程中产生横向偏移的问题,提出一种RTG大车速度差自动纠偏方法。该方法通过磁尺传感器采集RTG大车横向偏移距离和偏移角,建立RTG大车横向偏移数学模型。基于最优控制理论构建运行性能指标函数,推导出最优控制矩阵的黎卡提方程并采用线性二次型最优控制方法求解。引入惯性、加减速、PLC延迟等干扰进行Simulink仿真,得到最终解。在现场调试中,PLC根据该代数解完成RTG大车行驶自动纠偏。研究结果表明:大车横向偏移距离保持在30 mm内,实际运行效果理想,达到RTG大车自动纠偏目的。
关键词:
轮胎式龙门起重机(RTG); 速度差自动纠偏; 最优控制理论; 黎卡提方程
中图分类号: U653.921; TP27
文献标志码: A
收稿日期: 2019-11-11
修回日期: 2020-08-19
基金项目:
国家自然科学基金(71701126)
作者简介:
杨阳(1983—),女,上海人,讲师,硕导,博士,研究方向为物流工程与管理, (E-mail)yyang@shmtu.edu.cn
Automatic deviation correction system design and
deviation correction strategy for RTG cart
YANG Yang, WANG Baolei, HAN Jiaqi
(Logistics Engineering College, Shanghai Maritime University, Shanghai 201306, China)
Abstract:
To solve the rubber-tyred gantry crane (RTG) cart transverse deviation problem in the straight-line driving, a method of automatic deviation correction for RTG cart velocity difference is proposed. Based on the data of transverse deviation displacement and deviation angle collected by the magnetic ruler sensor, the mathematical model of the RTG cart transverse deviation is established. The operational performance index function is constructed based on the optimal control theory, and the Riccati equation of the optimal control matrix is derived and solved by the linear quadratic optimal control method. The Simulink simulation is carried out to obtain the final solution, where the interference of inertia, acceleration, deceleration and PLC delay is introduced. In the field experiment, the PLC automatically corrected the RTG cart travelling deviation according to the algebraic solution. The results show the RTG cart transverse deviation displacement is kept within 30 mm, the actual operation effect is ideal, and the purpose of automatic deviation correction is achieved.
Key words:
rubber-tyred gantry crane (RTG); automatic deviation correction for velocity difference; optimal control theory; Riccati equation
0 引 言
輪胎式龙门起重机(rubber-tyred gantry crane, RTG)是目前国内集装箱码头堆场搬运、装卸、堆垛等作业的专用机械。相比于轨道式龙门起重机(rail-mounted gantry crane, RMG),RTG的机动性较好、通用性较强,可以进行跨箱区作业。
由于RTG没有轨道约束,偏斜行驶会产生剐箱、撞箱等问题,甚至造成严重的损失。
为实现码头自动化转型升级,对RTG的自动化改造的关键就是解决RTG大车自动纠偏问题。本文对RTG进行纠偏系统设计和纠偏策略研究。
针对起重机大车行驶的自动纠偏改造,国内学者提出了不同的技术方案:闫德鑫等[1]利用GPS定位计算当前RTG大车的偏移距离,并根据偏移距离推算纠偏控制量,但是纠偏效果欠佳。……
登录APP查看全文
猜你喜欢
小雪花·小学生快乐作文(2024年11期)2024-12-31 00:00:00
小猕猴智力画刊(2022年9期)2022-11-04 02:31:42
小主人报(2022年4期)2022-08-09 08:52:06
小哥白尼(趣味科学)(2019年6期)2019-10-10 01:01:50
发明与创新(2016年38期)2016-08-22 03:02:52
太空探索(2016年5期)2016-07-12 15:17:55
实验流体力学(2011年5期)2011-01-14 01:25:28
学与玩(2004年7期)2004-04-29 00:00:00