智能物料搬运机器人结构设计
2021-08-16 16:53:19张余龙邱夏东胡晓靖田祖祎
中小企业管理与科技·上旬刊
2021年8期
张余龙 邱夏东 胡晓靖 田祖祎

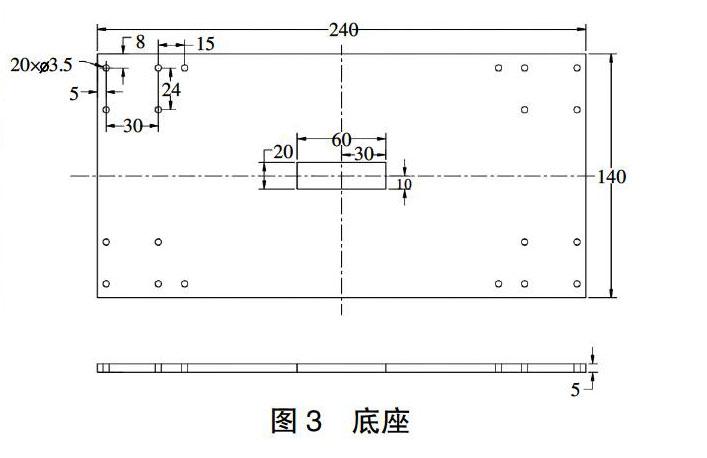
【摘 要】针对小型轻型物料搬运的市场需求,一款智能物料搬运机器人被设计出来。论文主要讨论了其机械结构部分的设计,包括总体布局、底座、车轮及机械手等,并建立三维模型和物理样机。样机试行过程中,运行平稳,物料不易脱落,表明设计方案可行,可为物料搬运机器人的结构设计提供参考。
【Abstract】In view of the market demand of small and light material handling, an intelligent material handling robot is designed. The paper mainly discusses the design of its mechanical structure, including the overall layout, the base, the wheel and the manipulator, and establishes the three dimensional model and physical prototype. During the trial run of the prototype, the operation is stable and the materials are not easy to fall off, which shows that the design scheme is feasible and can provide reference for the structural design of material handling robot.
【关键词】物料搬运机器人;麦克纳姆轮;机械手
【Keywords】material handling robot; Mecanum wheel; manipulator
【中图分类号】TP242.6 【文献标志码】A 【文章编号】1673-1069(2021)08-0185-02
1 引言
智能搬运机器人是指以嵌入式为控制基础,由电池提供能源,具备移动载物、自动导航、安全保护、路径规划等功能的无人搬运车[1]。智能搬运机器的设计与生产,集合了材料、机械、微处理器、智能算法等多个领域,涉及广泛的科学技术应用[2]。随着人类社会需求的发展,人力成本的上升,智能搬运机器人在日常的生活和工作领域起到越来越重要的作用。
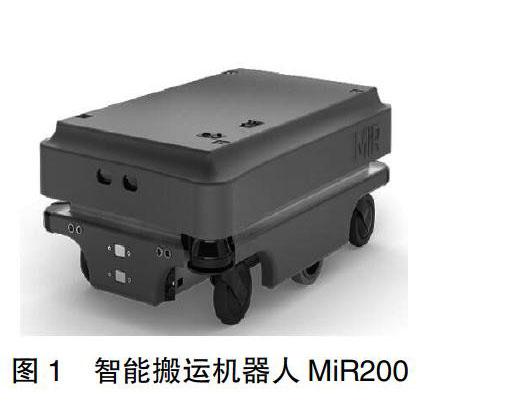
在商业和物流活动中,小型和轻型的物料在数量方面占据的份额最大[3]。因此,搬运机器人的相关研究一直受到业界重视。首台搬运机器人由Barret公司于20世纪50年代研制成功[4]。随着伺服驱动技术的成熟和计算机的普及,促进了控制系统技术的进步,不同类型的搬运机器人开始出现在市场上。1968年诞生了首台智能机器人,其具备自主感知和行为规划等功能。21世纪,搬运机器人向专业化、智能化、集成化的方向发展。如图1所示的MiR200机器人集成多重功能,最高负载可达200kg,并安装定制不同模块,如货架、举升装置、传送带甚至是协作机器人手臂来实现不同任务需求,并且可以识别障碍,规划路径,实现自主安全运行。……
登录APP查看全文