
基于树莓派深度学习的采摘机器人
2023-06-21 22:09:52覃书波胡美婧陈昌熙
现代信息科技
2023年1期
关键词:深度学习
覃书波 胡美婧 陈昌熙
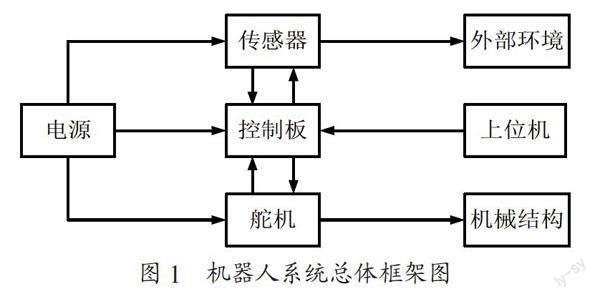

摘 要:为解决采摘机器人在抓取中的目标识别、位置定位及系统控制方面准确率低,自主能力差等问题。提出一种基于深度学习的采摘机器人,该机器人系统以树莓派为主控核心,结合舵机和多种传感器组等模块,通过建立机器人运动学模型,实现从关节到末端执行机构的映射,采用视觉技术建立目标识别与定位模型,通过视觉反馈来控制机器人。试验结果表明,该机器人具有较高的识别能力与定位准确率,并具有较高的控制效率。
关键词:采摘机器人;深度学习;运动学模型;LeNet卷积神经网络;PID算法
中图分类号:TP242 文献标识码:A 文章编号:2096-4706(2023)01-0154-05
Picking Robot Based on Deep Learning of Raspberry Pie
QIN Shubo1, HU Meijing2, CHEN Changxi3
(1.School of Electrical and Information Engineering, Anhui University of Science and Technology, Huainan 232001, China;
2.School of Earth and Environment, Anhui University of Science and Technology, Huainan 232001, China;
3.School of Computer and Engineering, Anhui University of Science and Technology, Huainan 232001, China)
Abstract: In order to solve the problems of low accuracy and poor autonomy of picking robot in aspects of target recognition, position positioning and system control in grasping, a type of picking robot based on deep learning is proposed. The robot system takes raspberry pie as control core, combined with the steering gear and a variety of sensor modules, through the establishment of the robot kinematics model, achieves the mapping from the joint to the end of the actuator. The vision technology is adopted to establish the target identification and positioning model, and it controls the robot through the visual feedback. The experimental results show that the robot has higher recognition ability and positioning accuracy, and has higher control efficiency.
Keywords: picking robot; deep learning; kinematic model; LeNet convolutional neural network; PID algorithm
0 引 言
作为农业生产大国,我国每年的果蔬产量巨大。果蔬的采摘必然成为一项重大任务,传统采摘方式仍然处于人工采摘阶段,不仅需要投入大量的人力物力还会存在人为因素造成的采摘不及时,误摘等现象,从而导致采摘成本的增加,效率的下降[1]。
近年来,自动化技术和人工智能技术迅猛发展,农业采摘也顺势由传统的人工采摘转变为机械采摘,人工智能的进步,使得越来越多的机器人、机械臂应用到农业采摘中,极大地提高了农业生产效率[2,3]。但利用机器人进行采摘的过程中,对目标对象的识别不准确,定位有误差,以及控制不稳定都会使采摘更困难,造成采摘效率的下降[4]。因此如何进一步提高采摘的效率成为众多学者研究的一个热点,目前,圖像处理技术的发……
登录APP查看全文
猜你喜欢
中国教育技术装备(2016年19期)2016-12-27 19:23:52
中国远程教育(2016年11期)2016-12-27 18:07:31
现代商贸工业(2016年25期)2016-12-26 09:58:02
江苏教育·中学教学版(2016年11期)2016-12-21 11:45:08
江苏教育·中学教学版(2016年11期)2016-12-21 11:36:29
现代情报(2016年10期)2016-12-15 11:50:53
考试周刊(2016年94期)2016-12-12 12:15:04
新教育时代·教师版(2016年23期)2016-12-06 06:02:38
法制与社会(2016年32期)2016-12-01 15:25:53
软件导刊(2016年9期)2016-11-07 22:20:49
