基于KNN算法的船舶操纵智能评估系统
2021-01-06 09:25:38张叶任鸿翔王德龙
上海海事大学学报
2021年4期
关键词:评价指标
张叶 任鸿翔 王德龙
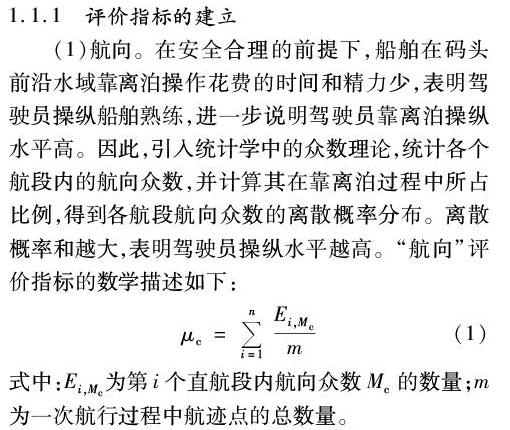

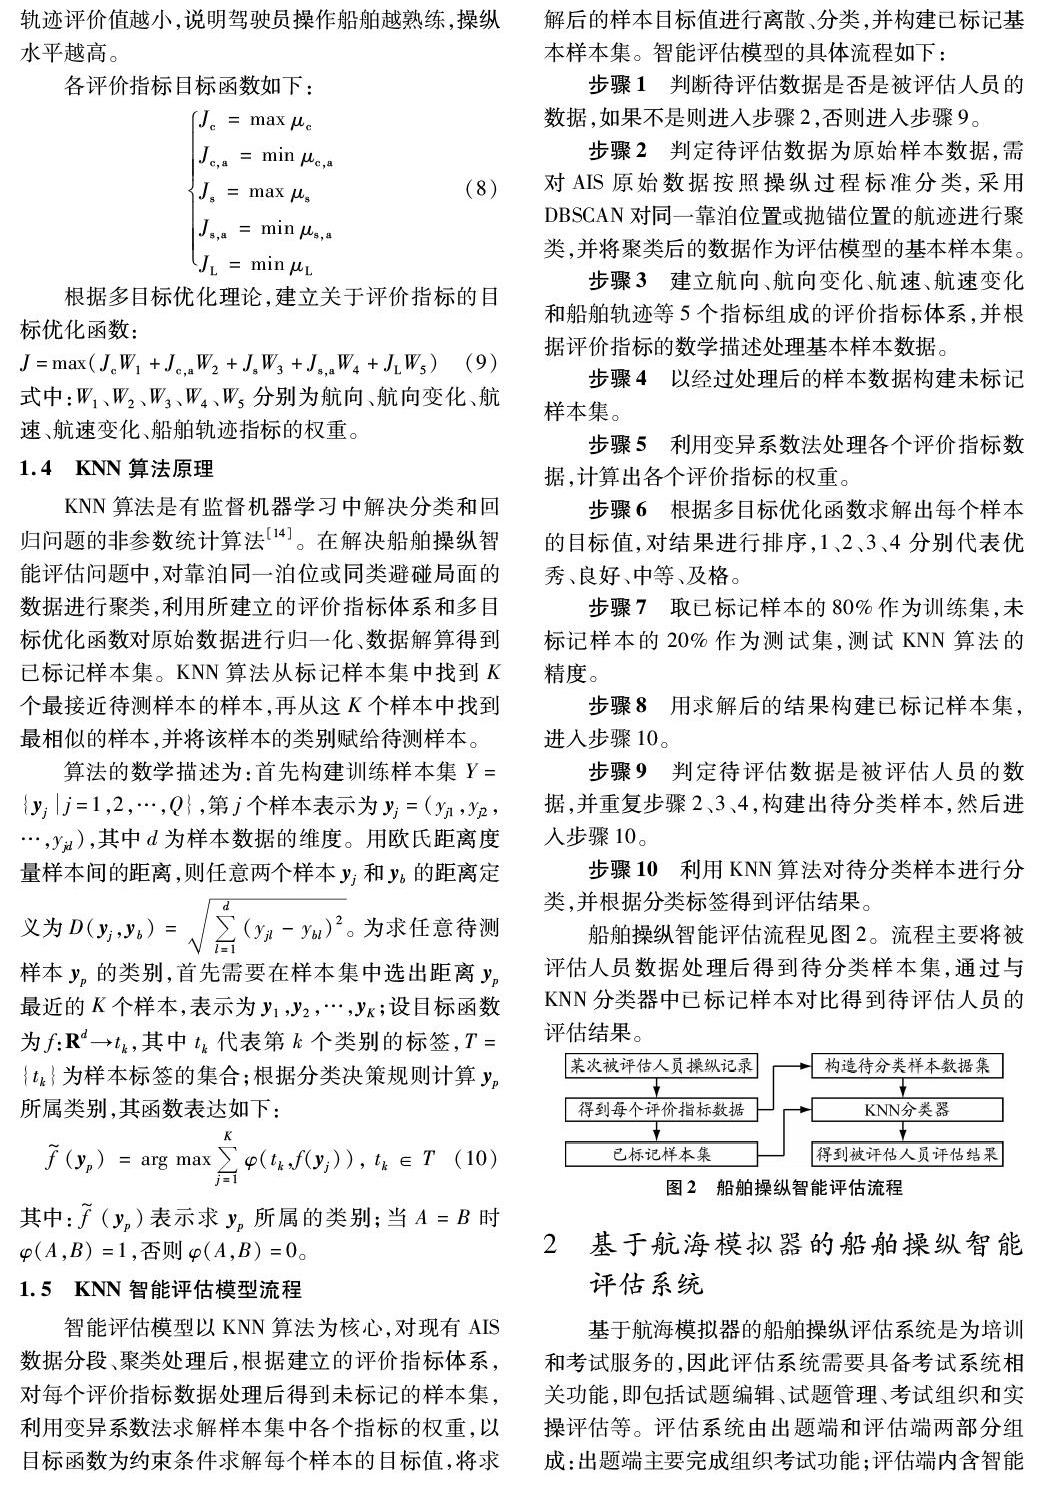
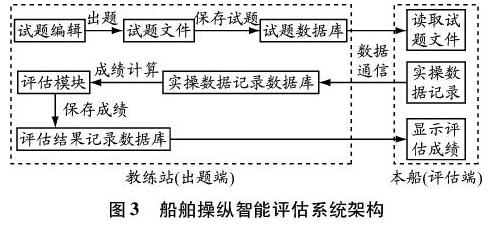
摘要:为降低主观因素对船舶操纵评估结果的影响,提出一种基于K近邻(K-nearest neighbor, KNN)算法和多目标优化理论的船舶操纵智能评估模型。根据安全、平稳、高效的航行要求,建立这个模型的评价指标体系;采用变异系数法获得各评价指标的权重;根据评价指标提取对应特征值,构建未标记样本集;基于多目标优化理论建立评价指标目标函数,得到每个样本的成绩并排序,根据样本成绩构建标记样本集;利用KNN算法对待评估样本进行分类,得到本次操作的结果。利用C+ +语言开发船舶操纵智能评估系统,测试结果表明,系统评估结果与专家评估结果基本一致,能客观、准确实现船舶操纵自动评估。
关键词: K近邻(KNN)算法; 船舶操纵评估; 智能评估系统; 航海模拟器; 评价指标
中图分类号: U666.158 文献标志码: A
Abstract: In order to reduce the impact of subjective factors on ship maneuvering evaluation results, an intelligent evaluation model for ship maneuvering is put forward based on the K-nearest neighbor (KNN) algorithm and the multi-objective optimization theory. The evaluation index system of the model is established according to the safe, stable and efficient navigation requirements. The weights of evaluation indices are obtained by the coefficient of variation method. The unlabeled sample set is constructed by extracting relevant characteristic values according to evaluation indices. The evaluation index objective function is established based on the multi-objective optimization theory, the sample scores are obtained and sorted, and the labeled sample set is constructed based on the sample scores. The KNN algorithm is used to classify the samples to be evaluated and get the evaluation score. The C+ + language is used to develop the intelligent evaluation system for ship maneuvering. Test results show that the system evaluation results are basically consistent with the expert evaluation results. The system can objectively and accurately realize the automatic evaluation of ship maneuvering.
Key words: K-nearest neighbor (KNN) algorithm; ship maneuvering evaluation; intelligent evaluation system; navigation simulator; evaluation index
0 引 言
STCW78/95公約马尼拉修正案将对船舶驾驶员采用船舶操纵模拟器进行训练和考核的要求列入了船员业务培训的范围。我国船员理论考试已实现上机考试,而船员操纵实操评估仍然采用评估员现场评估方式,评估工作量大[1],评估结果易受评估员主观因素影响。为实现船舶操纵的自动评估,国内外学者已经做了很多研究工作,如:陈锦标等[2]利用灰色模糊综合评价法建立了大型船舶操纵评估模型;薛满福等[3]利用模糊综合评价法建立了船舶靠离泊评估模型;王德龙等[4-5]构建了基于航海模拟器的船舶操纵和避碰自动评估系统;蒋效彬等……
登录APP查看全文
猜你喜欢
中国科技纵横(2016年20期)2016-12-28 15:26:00
经济研究导刊(2016年30期)2016-12-24 09:10:04
电脑知识与技术(2016年27期)2016-12-15 19:03:28
时代金融(2016年29期)2016-12-05 15:43:24
科学与管理(2016年5期)2016-12-01 19:18:45
中国市场(2016年40期)2016-11-28 04:01:18
商(2016年33期)2016-11-24 23:50:25
中小企业管理与科技·上旬刊(2016年10期)2016-11-15 09:44:40
中国市场(2016年38期)2016-11-15 00:01:08
中国市场(2016年33期)2016-10-18 13:33:29